Smart-PUFFIN
Smart Positioning Underwater system For environmental Field using artificial INtelligence
OUR MISSION
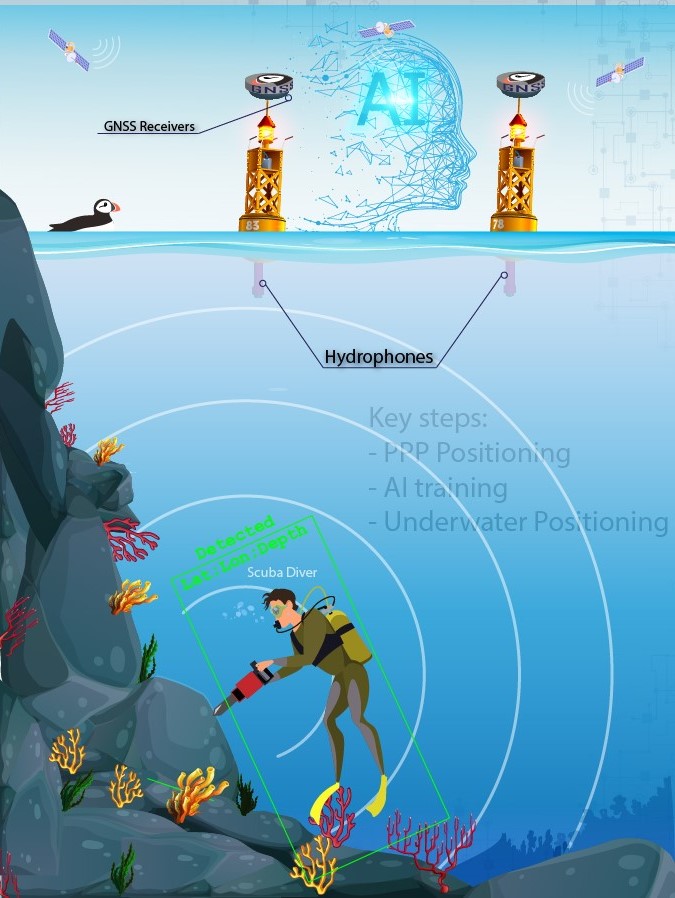
Our primary objective is the development of an intelligent underwater positioning system, dubbed Smart-PUFFIN (Smart Positioning Underwater system For environmental Field using artificial Intelligence), aimed at enhancing monitoring efforts within Marine Protected Areas (MPAs) along the Italian coastline.
This system will comprise buoys or Unmanned Surface Vehicles (USVs) equipped with GNSS (Global Navigation Satellite System) sensors to accurately determine the position of the buoy and maintain a stable and precise time scale. Additionally, omnidirectional hydrophones will be employed to capture and record underwater sounds. Leveraging advanced machine learning and deep learning techniques, we intend to process acoustic signals, classify underwater sounds, and correlate identical sounds across various acquired tracks.
The system will possess the capability to detect both cooperative and non-cooperative targets, such as locating Remotely Operated Vehicles (ROVs) or identifying illicit activities such as hammering by mussel poachers. Furthermore, it will facilitate the tracking of marine mammal movement within specified areas of interest. Our objectives encompass the refinement of a precise positioning methodology utilizing Point Precise Positioning (PPP) techniques with cost-effective GNSS receivers and the integration of new services offered by the Galileo satellite constellation. We also aim to train machine learning algorithms for the accurate recognition and classification of collected sounds and to employ the Time Differences Of Arrival (TDOA) approach to determine the geographical coordinates of specific sound sources with precision.
Moreover, we will rigorously evaluate the system’s accuracy and precision across simulated and real-world environments to ensure its efficacy in practical applications.
RESEARCH UNITS
Our Organizations
The project is supported by the joint collaboration of Research Units from three Italian University.
Università degli Studi di NAPOLI “Parthenope”
GNSS Precise Positioning of the buoys.
Principal investigator: DEL PIZZO Silvio
Università degli Studi di SALERNO
Machine/Deep Learning algorithm developing.
Associated investigator: NARDUCCI Fabio
Università degli Studi di MESSINA
Underwater Positioning using TDOA approach.
Associated investigator: ANGRISANO Antonio
THE TEAM LEADERS
People
DEL PIZZO Silvio
Project leader and the scientific coordinator of Università degli Studi di NAPOLI “Parthenope”.
Contact us
DEL PIZZO Silvio
silvio.delpizzo@uniparthenope.it
NARDUCCI Fabio
fnarducci@unisa.it
ANGRISANO Antonio
antonio.angrisano@unime.it